Dr.
Adriano Cavalcanti
Associate
Professor
|
Contact
St. Cloud State University
Department of Computer
Science and Information Technology (CSIT)
Engineering
and Computing Center 246
720 Fourth Ave. S, St.
Cloud, MN 56301, USA
Phone: (320) 308-4734
Email: adriano.cavalcanti@stcloudstate.edu
Education
Ph.D. Monash University,
Australia 2010 - Biomedical Engineering
Area of concentration: Robotics and Computational Nanotechnology
Teaching
SE 210 - Operating Systems
and Applications
CS 300 - Group Work for
Computer Science Projects
CS 310 - Introduction to
Operating Systems
CS 311 - Systems
Programming
CS 312 - Fundamentals of
Distributed Systems
SE 350 - Software
Engineering and Human Computer Interaction
CS 400 - Undergraduate
Research/Scholarly Activity
SE 475 - Software
Construction
SE 480 - Software Project
Management
SE 413/513 - Big Data
Organization and Management
CS 451/551 - Brain
Computer Interface
SE 460/560 - Software
Analysis
CS 495/595 - Brain
Robotics Interface
CS 593 - Preparatory
Systems Software
SE 640 - Foundations of
Software Engineering
CS 610 - Advanced Concepts
in Operating Systems
CS 444/644 - Internship:
Undergrad/Graduate Masters Level
CS 699 - Master's
Culminating Project
Research and Development Interests
My research interest is in
the field of Cybernetics, integrating
interdisciplinary topics and applications, comprising:
· Avatar
· Biomedical Computing
· Brain-Computer Interface
· Kubernetes
· Nanorobot/Robotics
· Spark
· TensorFlow
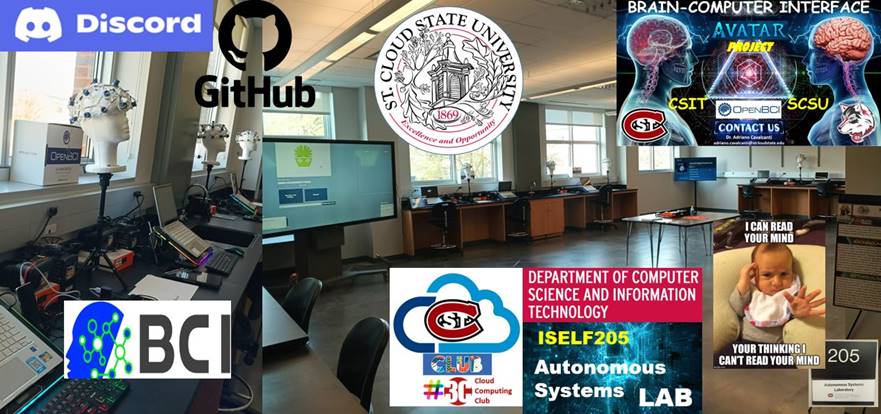
Ongoing
and past projects
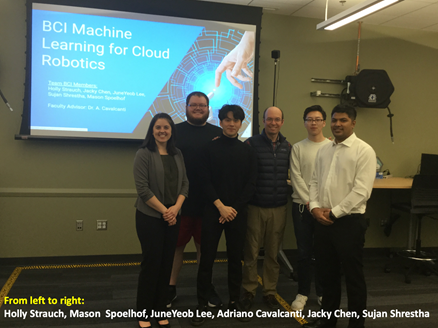
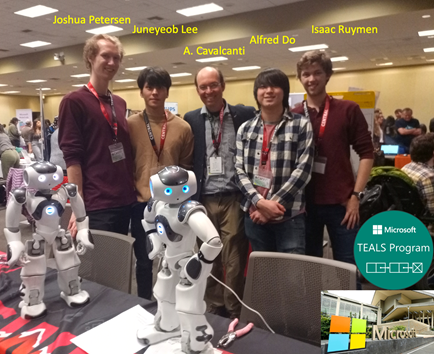
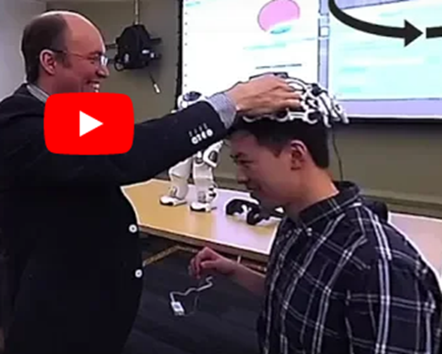
Note: for PC, watch the
video on Google Chrome moving the mouse or keyboard arrows; for Mobile devices
with Gyroscope, move the phone around you to change the angle of view.
Publications (Google Scholar)
Most Recent:
Ø Knudson, J., Cavalcanti,
A., & Singh, M. (2024) Neuro-Haptic
BCI Spark for TensorFlow Flying Avatars, 24th IEEE EIT
International Conference on Electro Information Technology, Eau Claire,
Wisconsin, USA, May.
Ø Theisen, B., Kang, D.,
Cavalcanti, A., & Hsiao, W. Y. (2024) Free Software for Institutional Review Board Compliance, 20th International
Conference on Technology, Knowledge, Society, Valencia, Spain, March.
Ø Hsiao, W. Y., &
Cavalcanti, A. (2024) Choosing the Right Robots for Young Children: A Study of
Technology for Early Childhood Education, 20th International
Conference on Technology, Knowledge, Society, Valencia, Spain, March.
Ø Hsiao, W. Y., Chiu, C. H.,
& Cavalcanti, A. (2024) Key
Strategies for Teaching Robotics to Kids, Society for Infomation Technology and Teacher Education (SITE), Las Vegas USA, March.
Ø Cavalcanti, A. (2023) Tutorial on TensorFlow Spark
for BCI Augmented Robotics, Midwest Instruction and Computing Symposium (MICS),
Cedar Falls IA, USA, April, 95-112.
Ø Knudson, J., Doyle, W., Hayen, M., & Cavalcanti, A. (2023) Kubernetes for High Performance BCI Flying Avatars, Minnesota State
Symposium, St.
Paul MN, USA, March.
In 2020:
Ø Cavalcanti, A., Huang, C.,
Nguyen, T., & Qin, S. (2020) Spark Facebook for Cloud
Brain Computer Interface, International Conference of
Advanced Research in Applied Science, Engineering and Technology, Houston TX,
USA, March.
Ø Cavalcanti, A., Murphy, D.
G., & Dasgupta, P. (2020) Nanorobot for Cancer Biomarker
Instrumentation, video, 15th IEEE NEMS Int'l
Conference on Nano/Micro Engineered & Molecular Systems, San Diego CA, USA,
September.
Ø Cavalcanti, A., Newhard, N., Harmsen, B., & Ruymen, I. (2020) Cloud Computing for
Humanoid Robotics Tele-immersion, video, Sixteenth International
Conference on Technology, Knowledge, and Society, Champaign IL, USA, October.
Previously by category
Journal - Peer Reviewed
Articles:
Ø Cavalcanti, A., Shirinzadeh, B., Fukuda, T., & Ikeda, S. (2009) Nanorobot for Brain Aneursym,
International Journal of Robotics Research, 28(4), 558-570.
Ø Cavalcanti, A., Shirinzadeh, B., & Kretly, L.
C. (2008) Medical
Nanorobotics for Diabetes Control, Nanomedicine:
Nanotechnology, Biology and Medicine, 4(2), 127-138.
Ø Cavalcanti, A., Shirinzadeh, B., Zhang, M., & Kretly,
L. C. (2008) Nanorobot Hardware Architecture
for Medical Defense, Sensors, 8(5), 2932-2958.
Ø Cavalcanti, A., Shirinzadeh, B., Freitas Jr., R. A., & Hogg, T.
(2008) Nanorobot Architecture for
Medical Target Identification, Nanotechnogloy,
19(1), 015103 (15p.).
Ø Cavalcanti, A., Shirnizadeh, B., Freitas Jr., R. A., & Kretly, L. C. (2007) Medical Nanorobot Architecture Based on Nanobioelectronics,
Bentham - Recent Patents on Nanotechnology, 1(1), 1-10.
Ø Cavalcanti, A., Freitas
Jr., R. A., & Kretly, L. C. (2005) Nanobotics Control Design: A
Practical Approach Tutorial, Robotics Today, Dearborn,
Mich.: SME Society of Manufacturing Engineers,
4th Quarter, 18(4).
Ø Cavalcanti, A., &
Freitas Jr., R. A., Nanorobotics
Control Design: A Collective Behavior Approach for Medicine (2005),
IEEE Transactions on Nanobioscience, 4(2), 133-140.
Ø Cavalcanti, A.
(2003) Assembly
Automation with Evolutionary Nanorobots and
Sensor-Based Control applied to Nanomedicine,
IEEE Transactions on Nanotechnology, 2(2), 82-87.
Ø Cavalcanti, A., &
Freitas Jr., R.A. (2003) Nanosystem Design with Dynamic Collision Detection for Autonomous Nanorobot Motion Control using Neural Networks, MEPhI -
Computer Graphics and Geometry, 5(1), 50-74.
Ø Cavalcanti, A., &
Freitas Jr., R. A. (2002), Autonomous Multi-robot
Sensor-Based Cooperation for Nanomedicine,
International Journal of Nonlinear Science and Numerical Simulation, 3(4),
743-746.
International Conference:
Keynote Speaker
Ø Cavalcanti, A.
(2014) Patient Care at
the Molecular Level, Panel Discussion, Biomedicine, Open
Innovations, Moscow, Russia.
Plenary Session - Peer
Reviewed Articles
Ø Cavalcanti, A.
(2005) Robots in
Surgery, Plenary Lecture, Euro Nano Forum 2005, Nanotechnology and
the Health of the EU Citizen in 2020, Edinburgh, Scotland, UK.
Ø Cavalcanti, A.
(2002) Neural Motion
and Evolutionary Decision in Robotic Competition applied for Molecular Machine
System Design, Plenary Lecture, Proceedings of the IEEE - CACSD
Int'l Conf. on Computer Aided Control System Design, Glasgow, Scotland, UK, 5-14.
Ø Cavalcanti, A., &
Freitas Jr., R. A. (2002) Nanosystem Design with Dynamic Collision Detection for Autonomous Nanorobot Motion Control using Neural Networks,
Plenary Lecture, in Proceedings of the ACM SIGGRAPH - Graphicon
Int'l Conf. on Computer Graphics, Novgorod, Russia, 75-80.
Full Paper - Peer Reviewed
Articles
Ø Cavalcanti, A., Shirinzadeh, B., Fukuda, T., & Seiichi, I. (2007) Hardware Architecture for Nanorobot Application in Cerebral Aneurysm, in
Proceedings of the IEEE Nano Int'l Conf. on Nanotechnology, Hong Kong, China,
237-242.
Ø Cavalcanti, A., Shirinzadeh, B., Hogg, T., & Smith, J. A. (2007) Hardware Architecture for Nanorobot Application in Cancer Therapy, in
Proceedings of the IEEE-RAS Int'l Conf. on Advanced Robotics, Jeju, Korea, 200-205.
Ø Cavalcanti, A., Shirinzadeh, B., Murphy, D., & Smith, J. A.
(2007) Nanorobots for Laparoscopic Cancer Surgery,
in Proceedings of the IEEE ICIS Int'l Conf. on Computer and Information
Science, Melbourne, Australia, 738-743.
Ø Cavalcanti, A., Hogg, T., Shirinzadeh, B., & Liaw, H.
C. (2006) Nanorobot Communication Techniques: A
Comprehensive Tutorial, in Proceedings of the IEEE ICARCV Int'l
Conf. on Control, Automation, Robotics and Vision, Grand Hyatt, Singapore,
2371-2376.
Ø Cavalcanti, A., Rosen, L.,
Shirinzadeh, B., & Rosenfeld, M. (2006) Nanorobot for Treatment of Patients with Artery
Occlusion, in Proceedings of the Springer Virtual Concept, Cancun,
Mexico.
Ø Cavalcanti, A., Wood, W.
W., Kretly, L. C., & Shirinzadeh,
B. (2006) Computational
Nanomechatronics: A Pathway for Control and Manufacturing Nanorobots,
in Proceedings of the IEEE CIMCA Int'l Conf. on Computational Intelligence for
Modelling, Control and Automation, IEEE Computer Sciety,
Sydney, Australia, 185-190.
Ø Cavalcanti, A., Hogg, T.,
& Shirinzadeh, B. (2006) Nanorobotics System Simulation in 3D
Workspaces with Low Reynolds Number, in Proceedings of the IEEE-RAS
MHS Int'l Symposium on Micro-Nanomechatronics and Human Science, Nagoya, Japan,
226-231.
Ø Cavalcanti, A., Hogg, T.,
& Kretly, L. C. (2005) Transducers Developoment
for Nanorobotic Applications in Biomedical
Engineering, in Proceedings of the IEEE NDSI Nanoscale Devices and
System Integration, Houston TX, USA.
Ø Cavalcanti, A., Rosen, L.,
Kretly, L. C., Rosenfeld, M., & Einav, S. (2004) Nanorobotic Challenges in Biomedical
Applications, Design and Control, in Proceedings of the IEEE ICECS
Int'l Conf. on Electronics, Circuits and Systems, Tel-Aviv, Israel.
Ø Lior Rosen, Vacalcanti, A., Rosenfeld, M., & Einav,
S. (2004) Pro-Inflammatory
Cytokines and Soluble Adhesion Molecules as Activating Triggers for Nanorobots, in Proceedings of the BMES Conf. on
Biomedical Engineering: New Challenges for the Future, Philadelphia PA, USA.
Ø Cavalcanti, A., Fretias Jr., R. A., & Kretly,
L. C. (2004) Nanorobotics
Control Design: A Practical Approach Tutorial, in Proceedings of
the ASME 28th Biennial Mechanisms and Robotics Conference, Salt Lake City Utah,
USA.
Ø Cavalcanti, A., &
Hogg, T. (2003) Simulating
Nanorobots in Fluids with low Reynolds Number,
in Proceedings of the 11th Foresight Conf. on Molecular Nanotechnology,
Burlingame CA, USA.
Ø Casal, A., Hogg, T., &
Cavalcanti, A. (2003) Nanorobots as Cellular Assistants in Inflammatory Responses,
in Proceedings of the IEEE BCATS Biomedical Computation at Standford
2003 Synposium, IEEE Computer Society, Stanford CA, USA.
Ø Cavalcanti, A.
(2003) Nanorobotics
Control Techniques with NanoCAD for Biomedical
Applications, in Proceedings of the Int'l Symposium Frontiers of NanoEngineering 2003, Campinas, Brazil, 24-27.
Ø Cavalcanti, A., &
Freitas Jr., R. A. (2002) Collective
Robotics Coherent Behaviour for Nanosystems
with Sensor-Based Neural Motion, in Proceedings of the IEEE - Int'l
Conf. on Artificial Intelligence Systems, IEEE Computer Society Press, Divnomorskoe, Russia, 185-190.
Ø Cavalcanti, A., &
Freitas Jr., R. A. (2002) Autonomous
Multi-robot Sensor-Based Cooperation for Nanomedicine,
in Proceedings of the ASME/IEEE ICMNS Int'l Conf. on Micro and Nano Systems,
Kunming, China, 139-142.
Ø Cavalcanti, A.
(2002) Assembly
Automation with Evolutionary Nanorobots and Senso-Based Control applied to Nanomedicine,
in Proceedings of the IEEE - Nano 2002 Int'l Conf. on Nanotechnology,
Washington D.C., USA, 161-164.
Short Paper:
Ø Cavalcanti, A., Shirinzadeh, B., Hogg, T., & Kretly,
L. C. (2006) CMOS-based
Nanorobot to Combat Cancer, in Proceedings
of the Australian Workshop on Fluid Mechanics, A Complex Dynamical System,
Melbourne, Australia.
Invited Seminar:
Ø Cavalcanti, A.
(2014) Nanorobot Hardware Architecture for Medical
Defense, Colloquium, Complex System Group, University of Alaska Anchorage,
Anchorage AK, USA.
Ø Cavalcanti, A.
(2005) Computational
Nanomechatronics for Nanorobots in Medicine,
Special Seminar, Department of Bioengineering, Rice University, Houston TX,
USA.
Ø Cavalcanti, A.
(2003) Nanorobotics:
Virtual Environments and Control Techniques, Seminary on Computer
Science, Computational Laboratory, ETH Zurich, Zurich, Switzerland.
Ø Cavalcanti, A.
(2002) Autonomous Nanorobotic Control for Competitive Molecular System Design,
Seminary in Dynamics, Department of Mechanical Engineering, Darmstadt
University of Technology, Darmstadt, Germany.